6 Degrees of Freedom Robotic Arm
Articulated robotic manipulator engineered for 1-meter reach and 200g payload capacity.
Thesis Overview
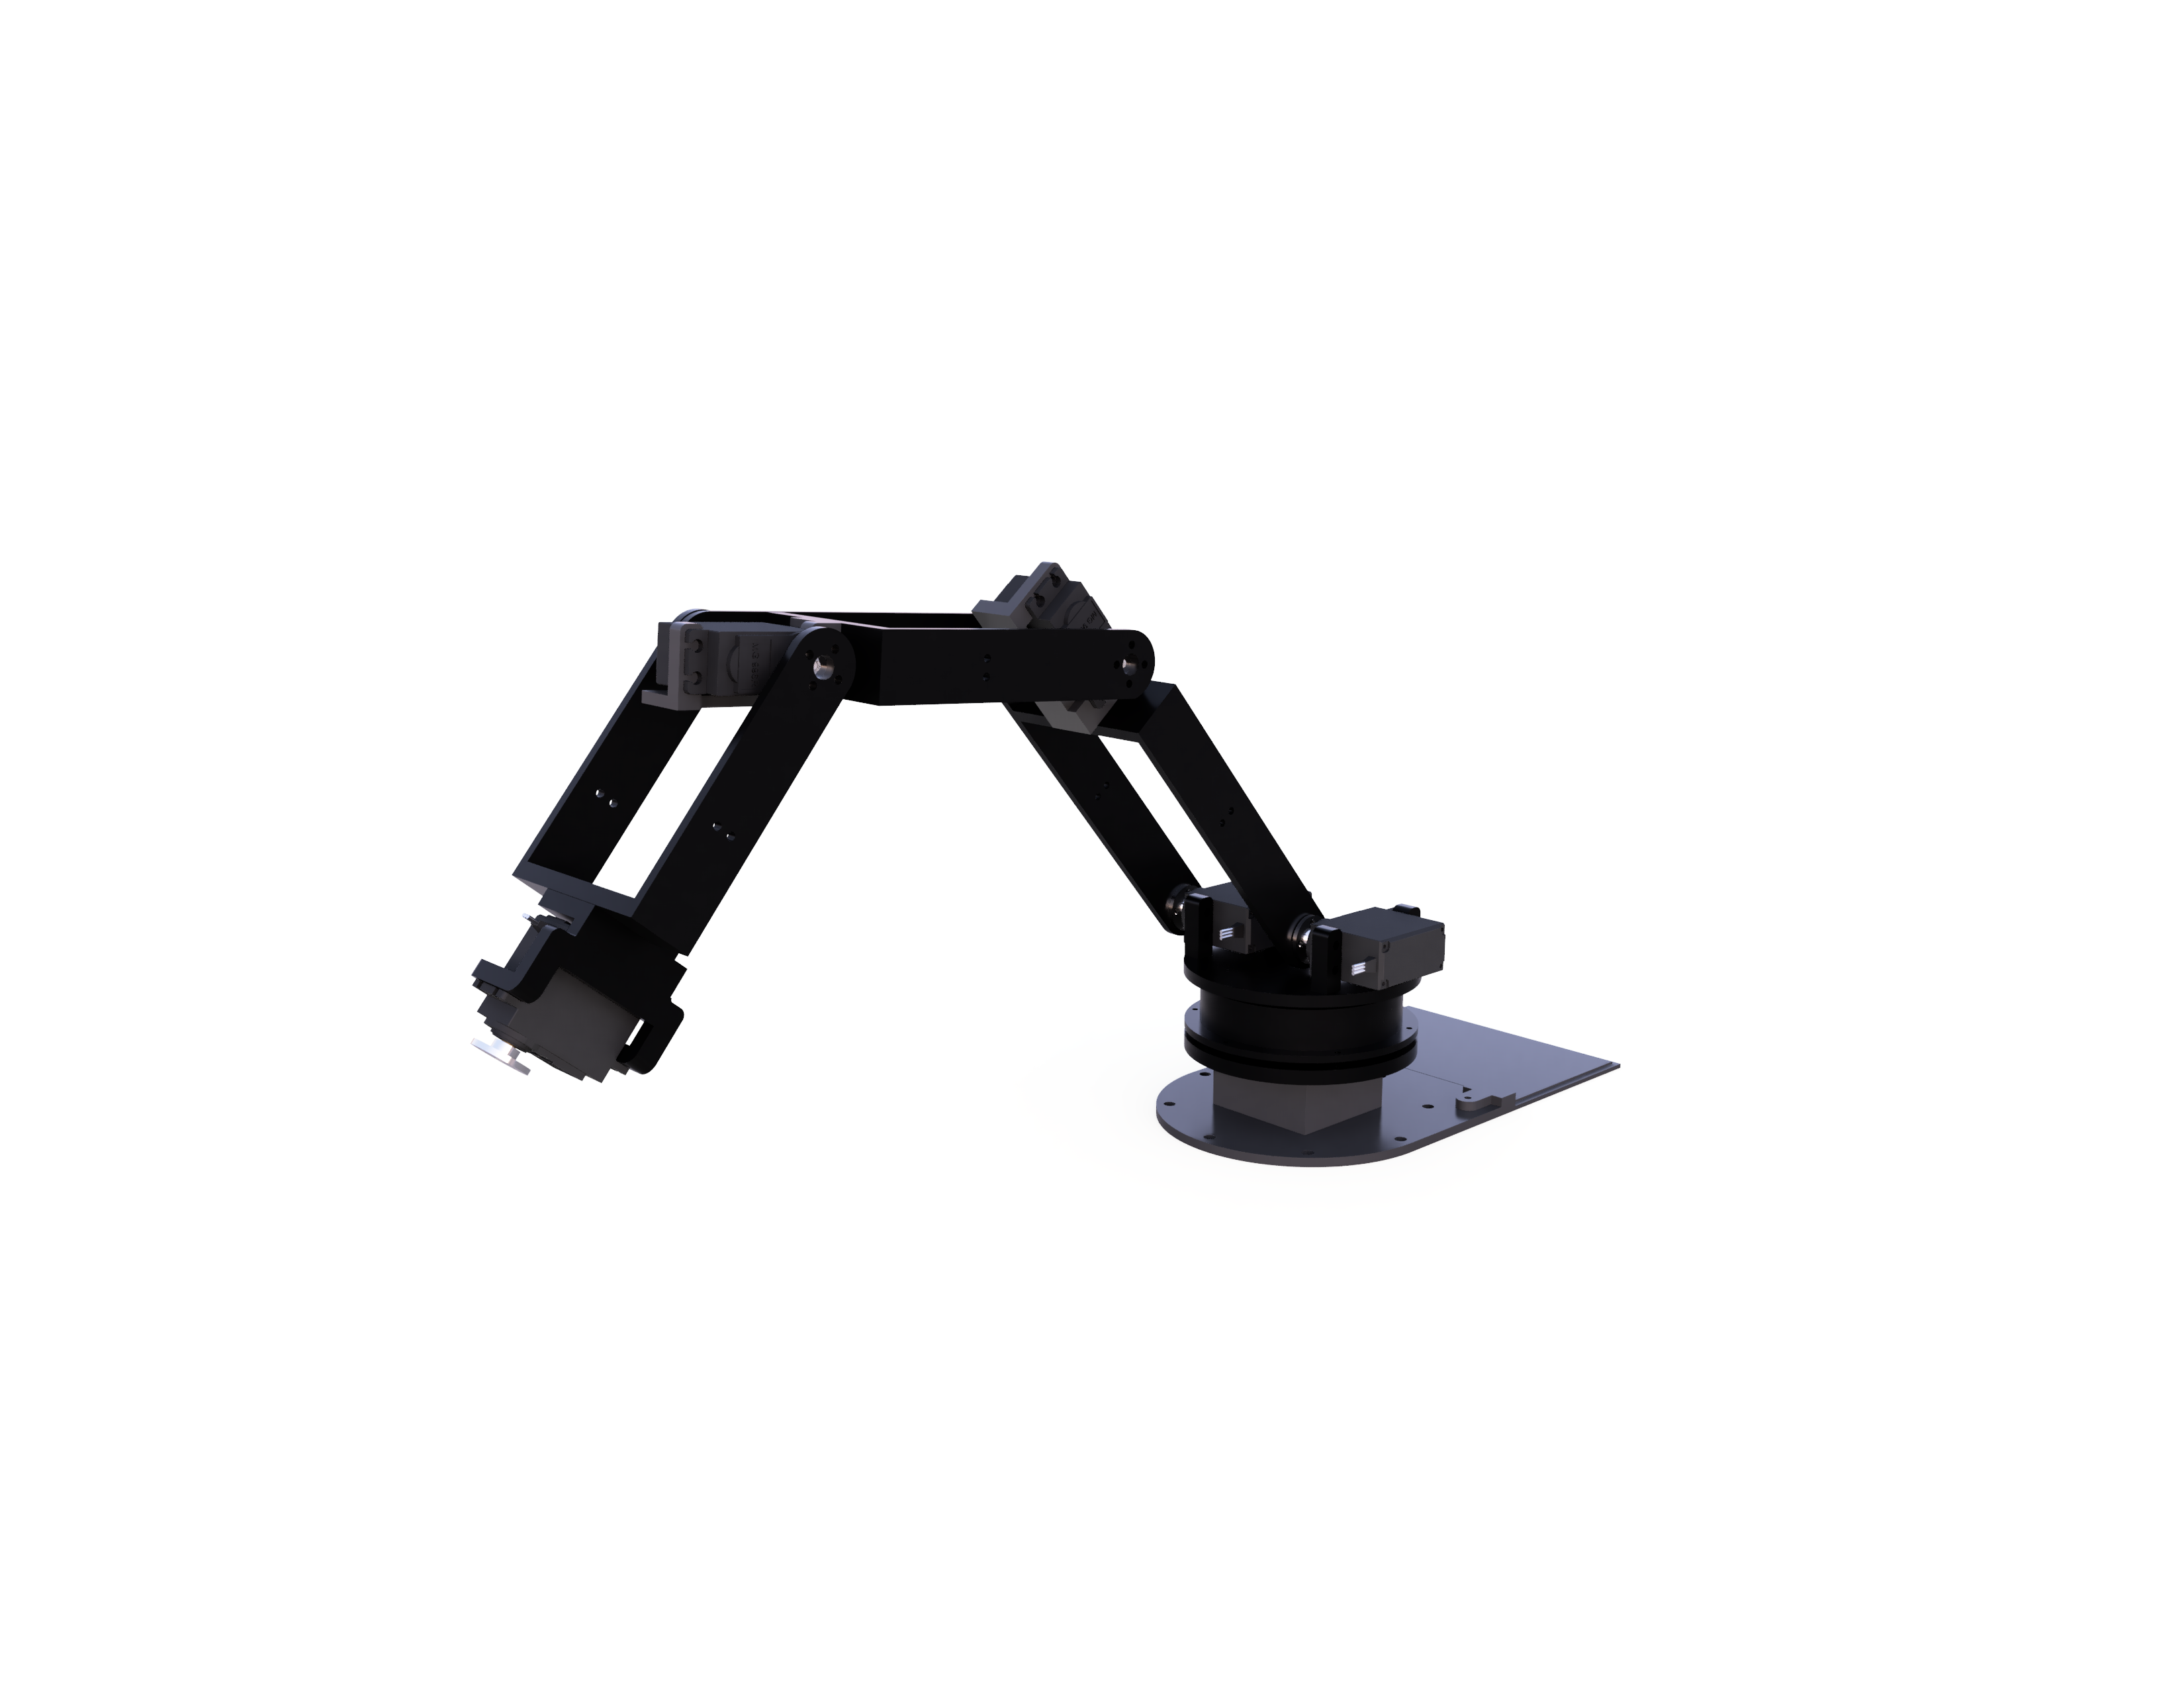
Developed as my BSc thesis project at the University of Thessaly, this robotic arm delivers full 6-axis articulation across a 1-meter working radius while carrying up to a 200-gram payload.
The mechanical base utilizes a high-torque stepper motor for 360° rotation, while the remaining 5 joint axes are driven by articulated high-resolution servo motors.
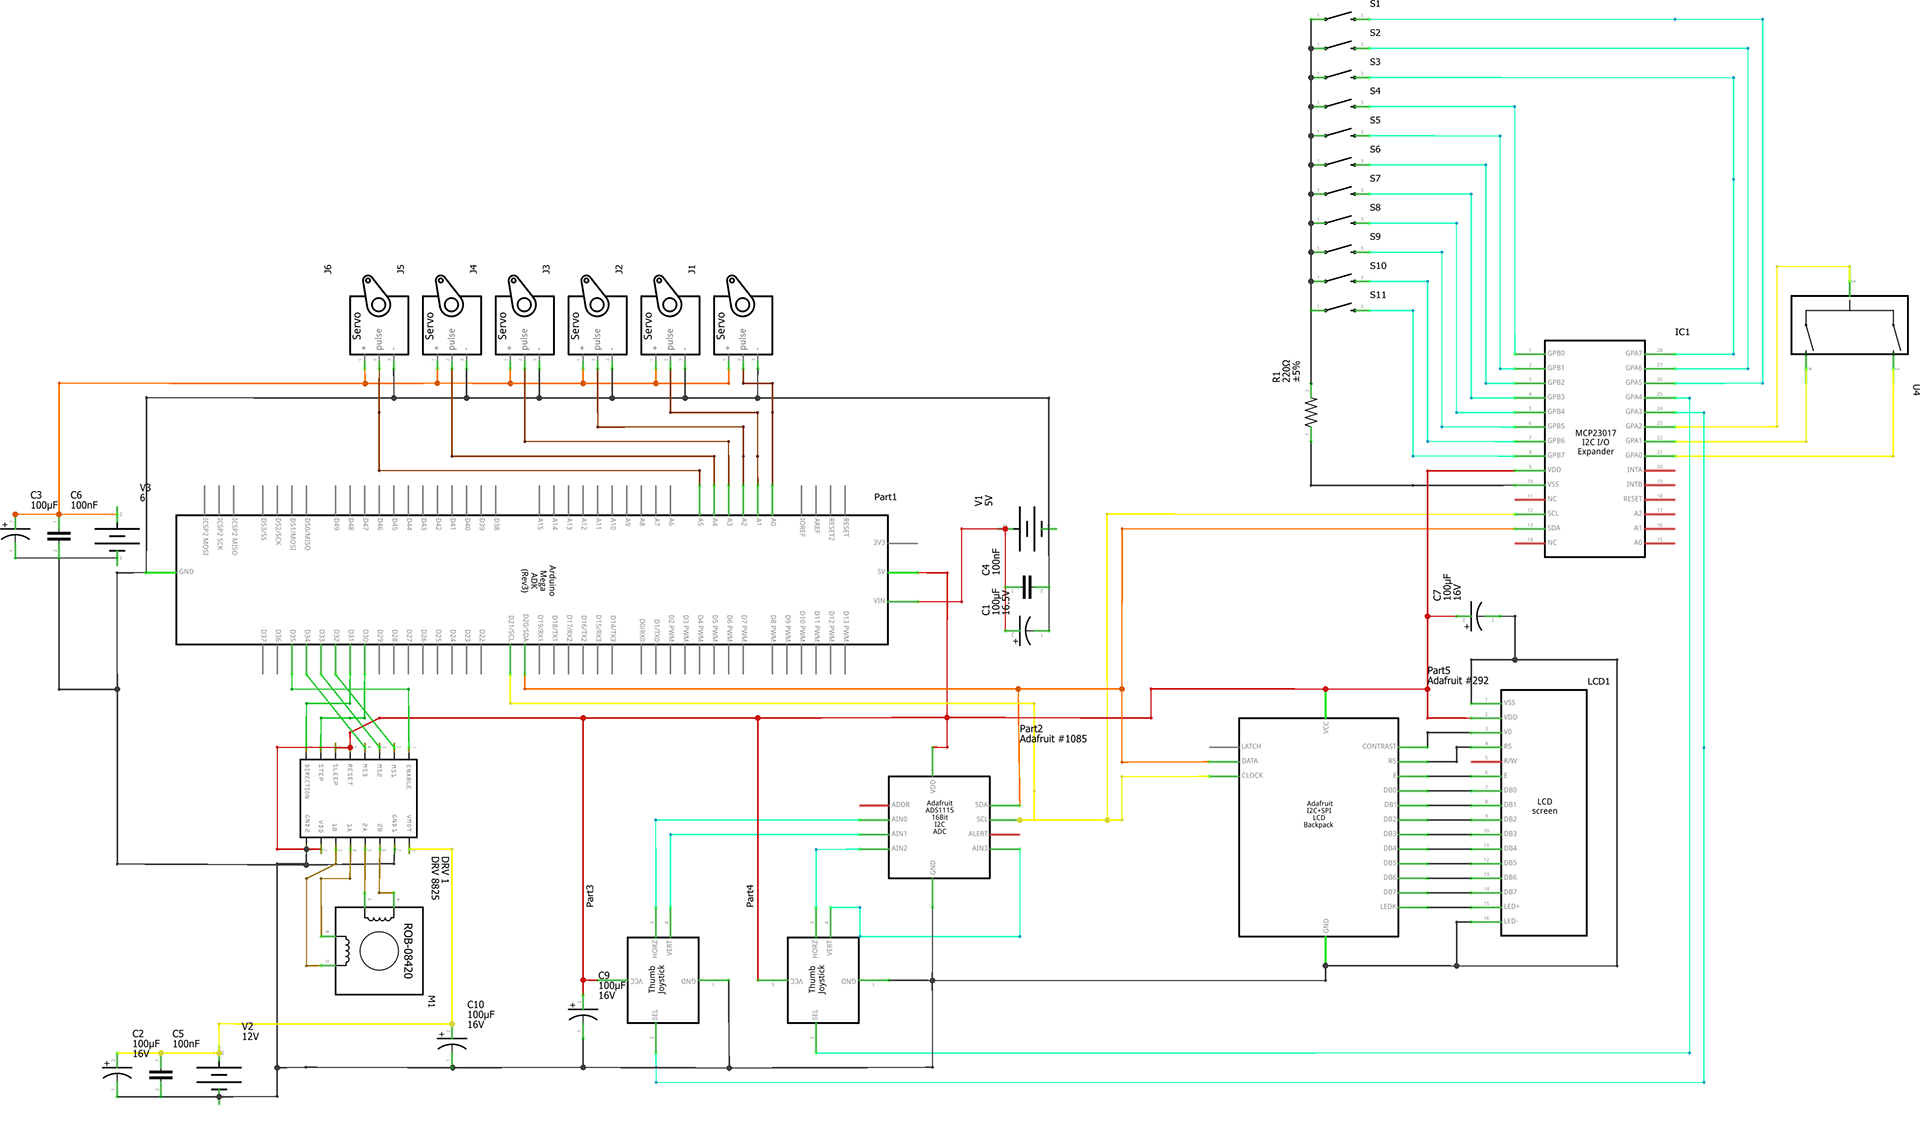
Control is implemented with inverse-kinematics routines and trajectory interpolation to generate smooth motion. The custom controller PCB provides motor drivers, current sensing for stall/protection, and a serial command interface for higher-level clients. Modes include position control, velocity control and a teach-playback mode used during testing.
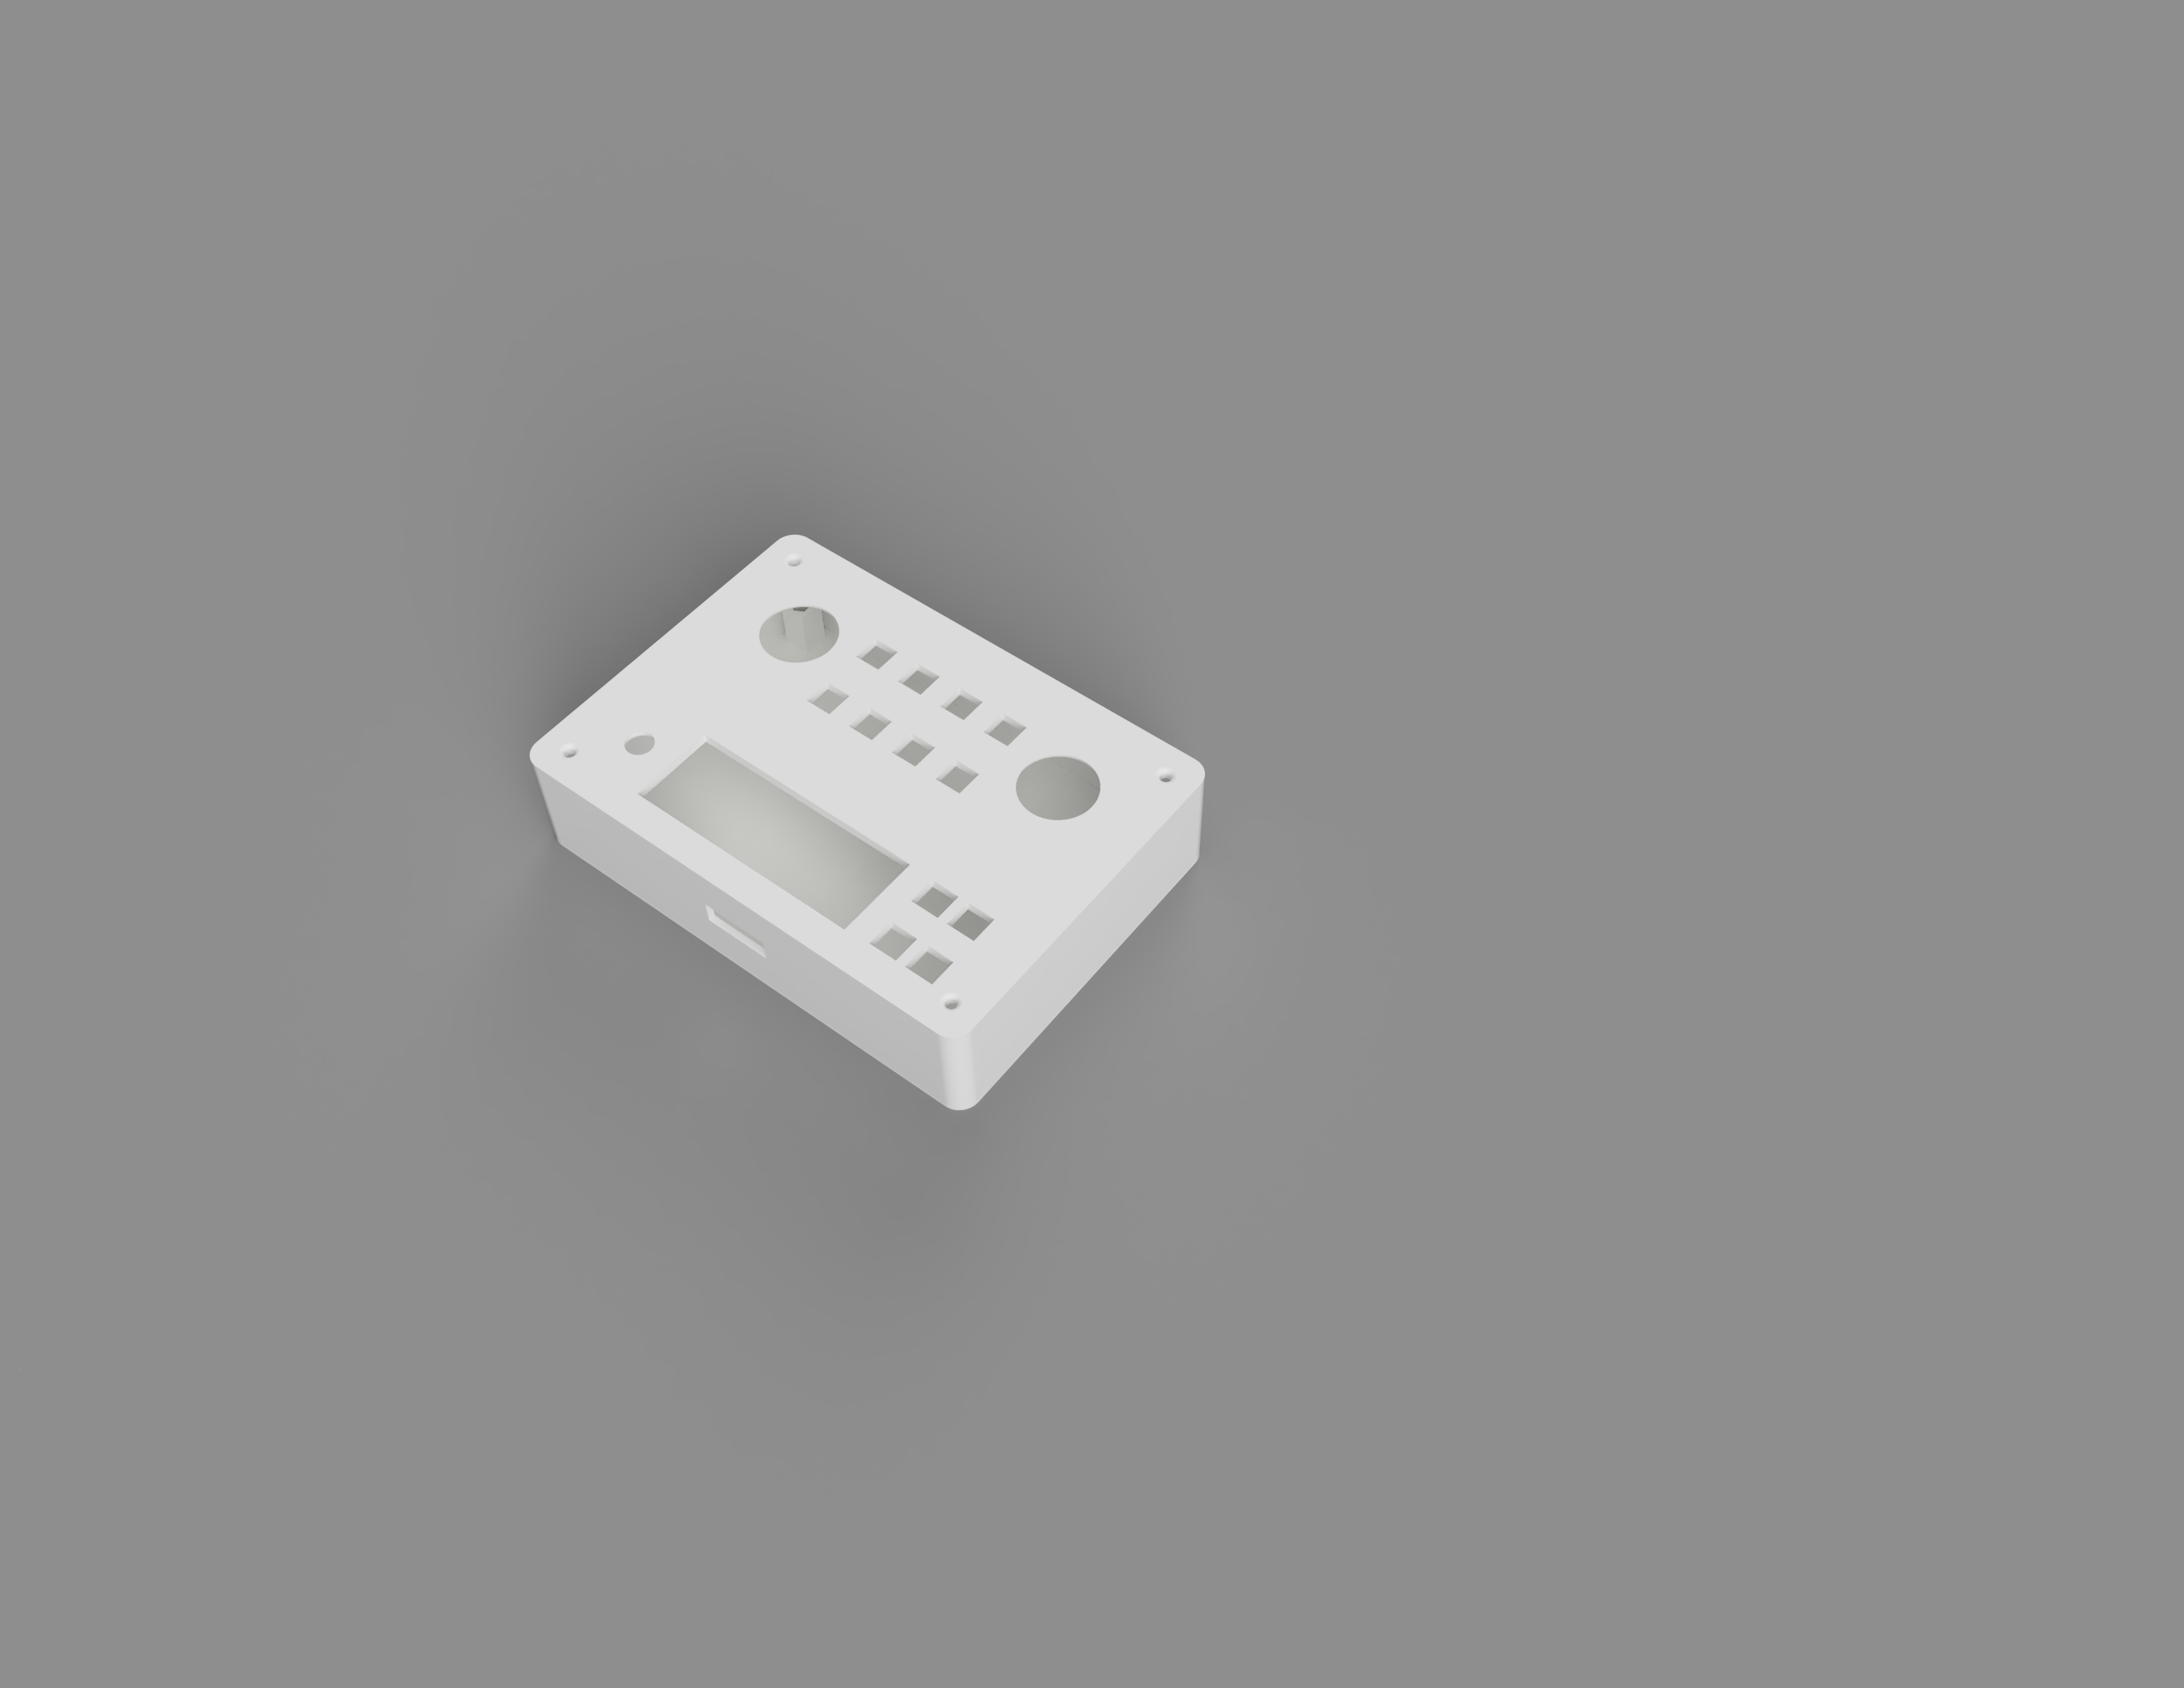
Controller Circuit Board
Circuit Schematic Details